|
Carlo Alessi Postdoctoral Researcher in Robot Learning I am a Postdoctoral Researcher in Robot Learning at the Italian Institute of Technology (IIT), where I am part of the Humanoid Sensing and Perception group led by Dr. Lorenzo Natale. My research focuses on deep learning for robot perception and manipulation, with applications in manufacturing and healthcare. I investigate imitation learning, reinforcement learning, and sim-to-real transfer across different robotic platforms, including humanoid robots, dexterous prosthetic hands, and continuum soft robotic arms. My research was funded by national and international projects: ergoCub (INAIL), FAIR (PNRR-MUR), and PROBOSCIS (Horizon 2020). Email / Google Scholar / LinkedIn / GitHub / |
|
Research |
|
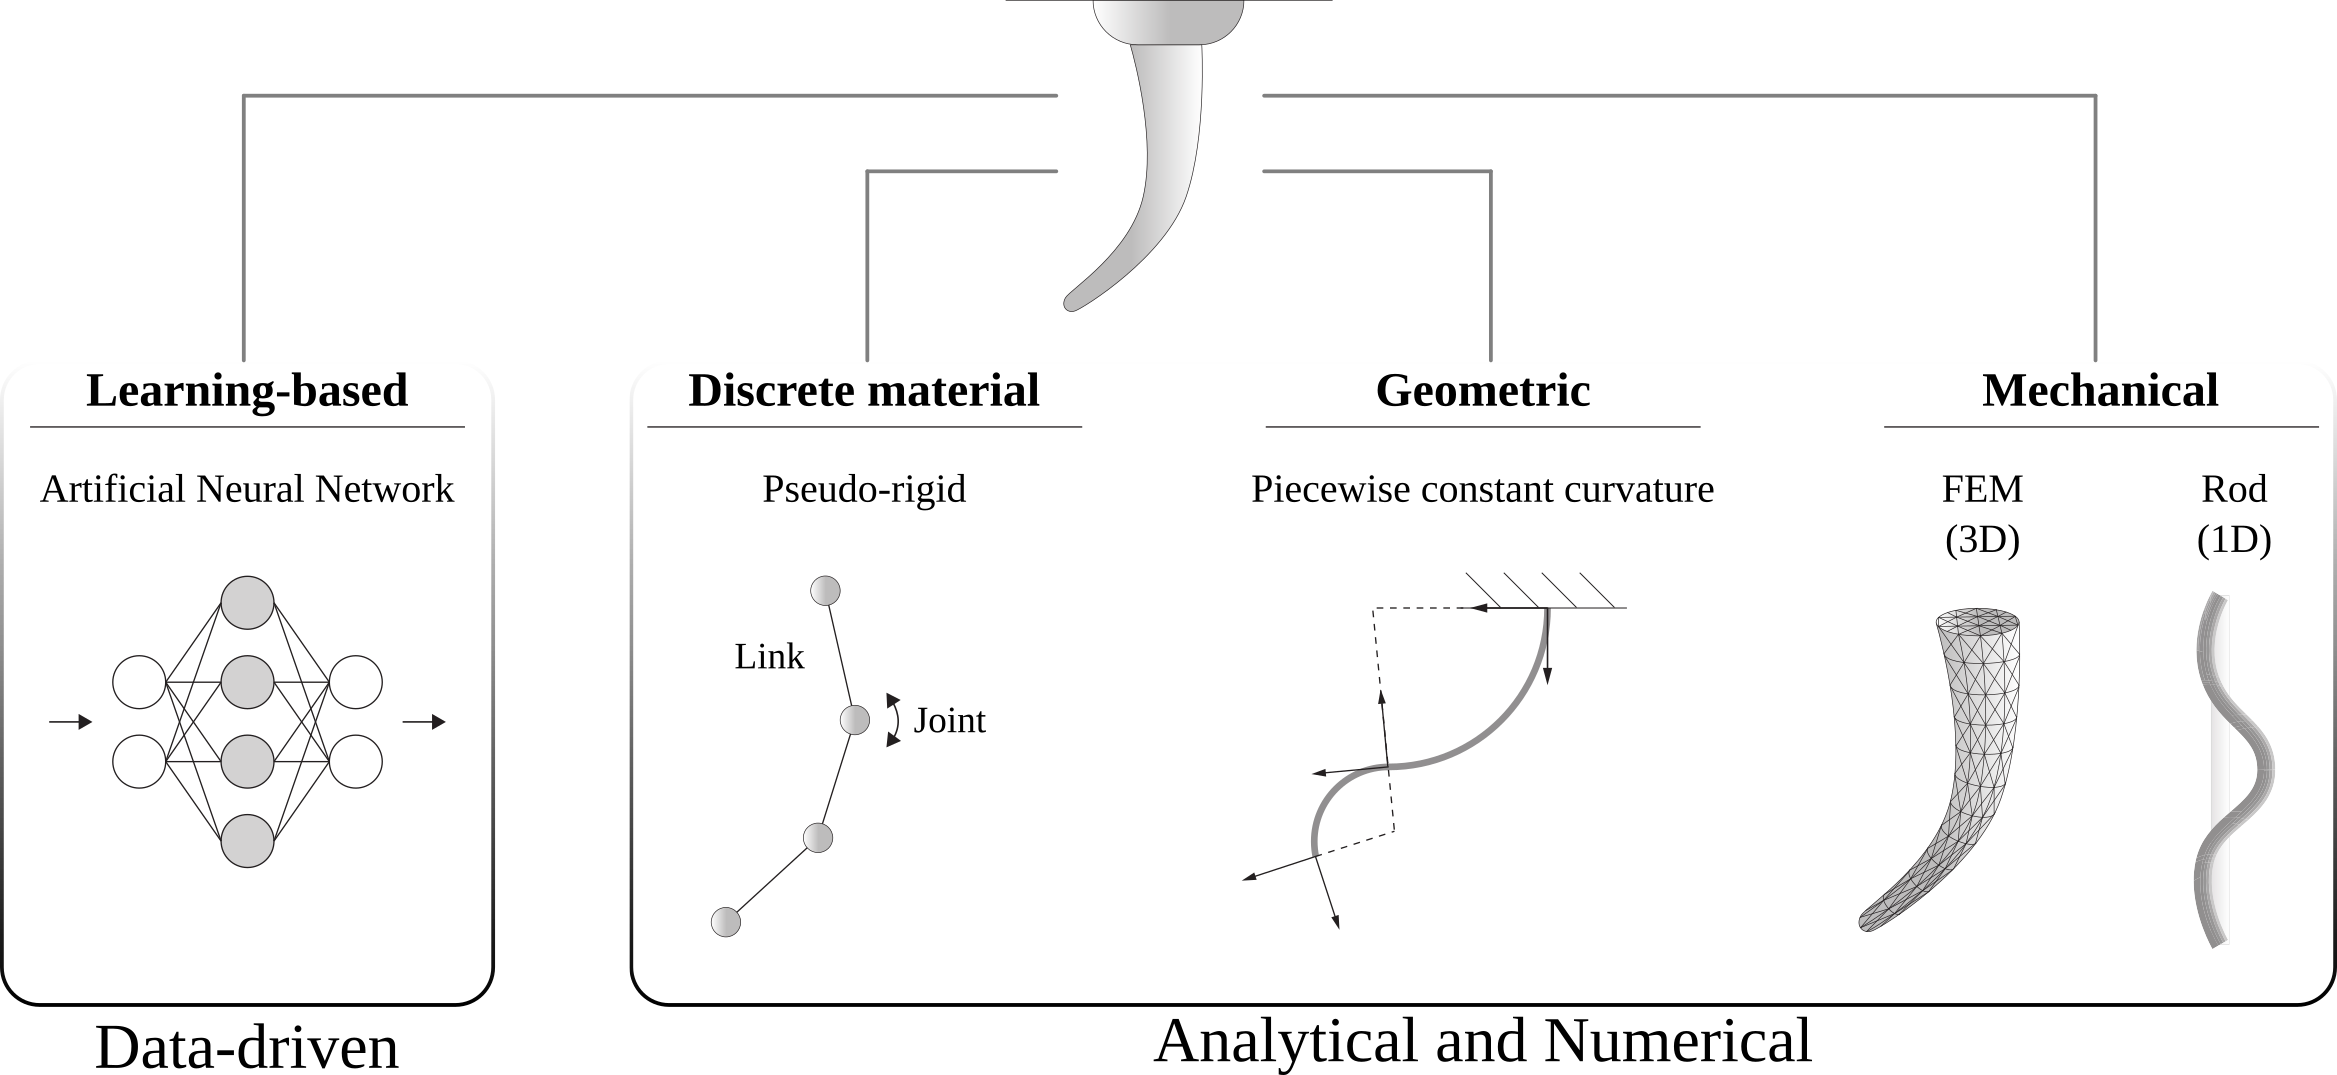
Rod Models in Continuum and Soft Robot Control: A Review
Carlo Alessi, Camilla Agabiti, Daniele Caradonna, Cecilia Laschi, Federico Renda, Egidio Falotico arXiv, 2026 Paper |
|
Zero-shot Whole-Body Manipulation with a Large-Scale Soft Robotic Torso via Guided Reinforcement Learning
Curtis C. Johnson, Carlo Alessi, Egidio Falotico, Marc D. Killpack arXiv, 2025 Paper / Video |
|
| 2025 |
Domain Translation of a Soft Robotic Arm using Conditional Cycle Generative Adversarial Network
Nilay Kushawaha, Carlo Alessi, Lorenzo Fruzzetti, Egidio Falotico International Conference on Robotic Systems and Applications (ICRSA), 2025 Paper |
|
HannesImitation: Grasping with the Hannes Prosthetic Hand via Imitation Learning
Carlo Alessi, Federico Vasile, Federico Ceola, Giulia Pasquale, Nicolò Boccardo, Lorenzo Natale IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025 Project Page / Paper / arXiv Trained a visuomotor Diffusion Policy to grasp objects with a prosthetic hand, using an RGB camera integrated into the palm and a controllable wrist. The policy is trained by behavior cloning on a dataset of grasp demonstrations collected in tabletop, shelf, and human-to-robot handover scenarios. |
|
|
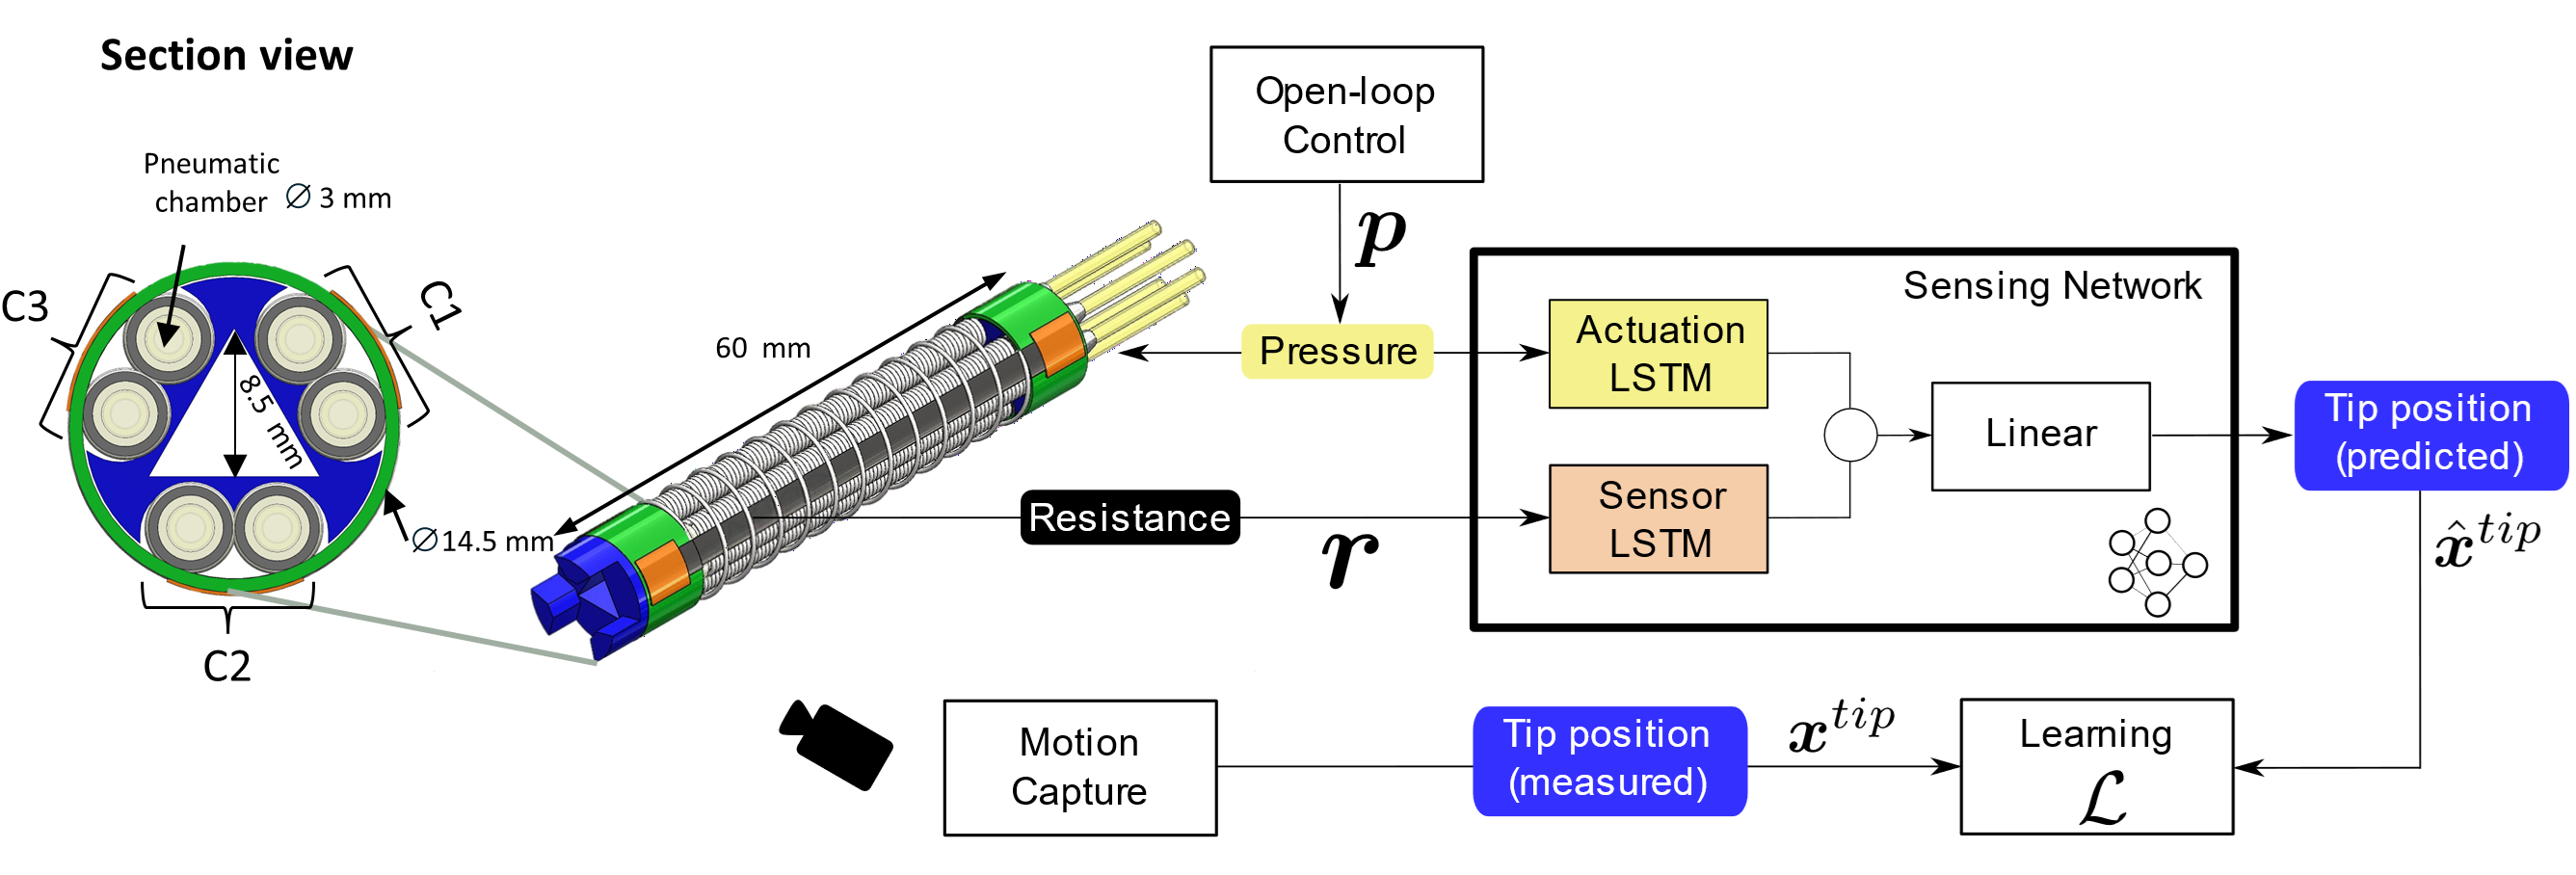
SoftTex: Soft Robotic Arm With Learning-Based Textile Proprioception
Niccolo Pagliarani, Carlo Alessi, Luca Arleo, Giulia Campinoti, Martina Maselli, Egidio Falotico, Matteo Cianchetti IEEE Robotics and Automation Letters, 2025 Paper / GitHub |
|
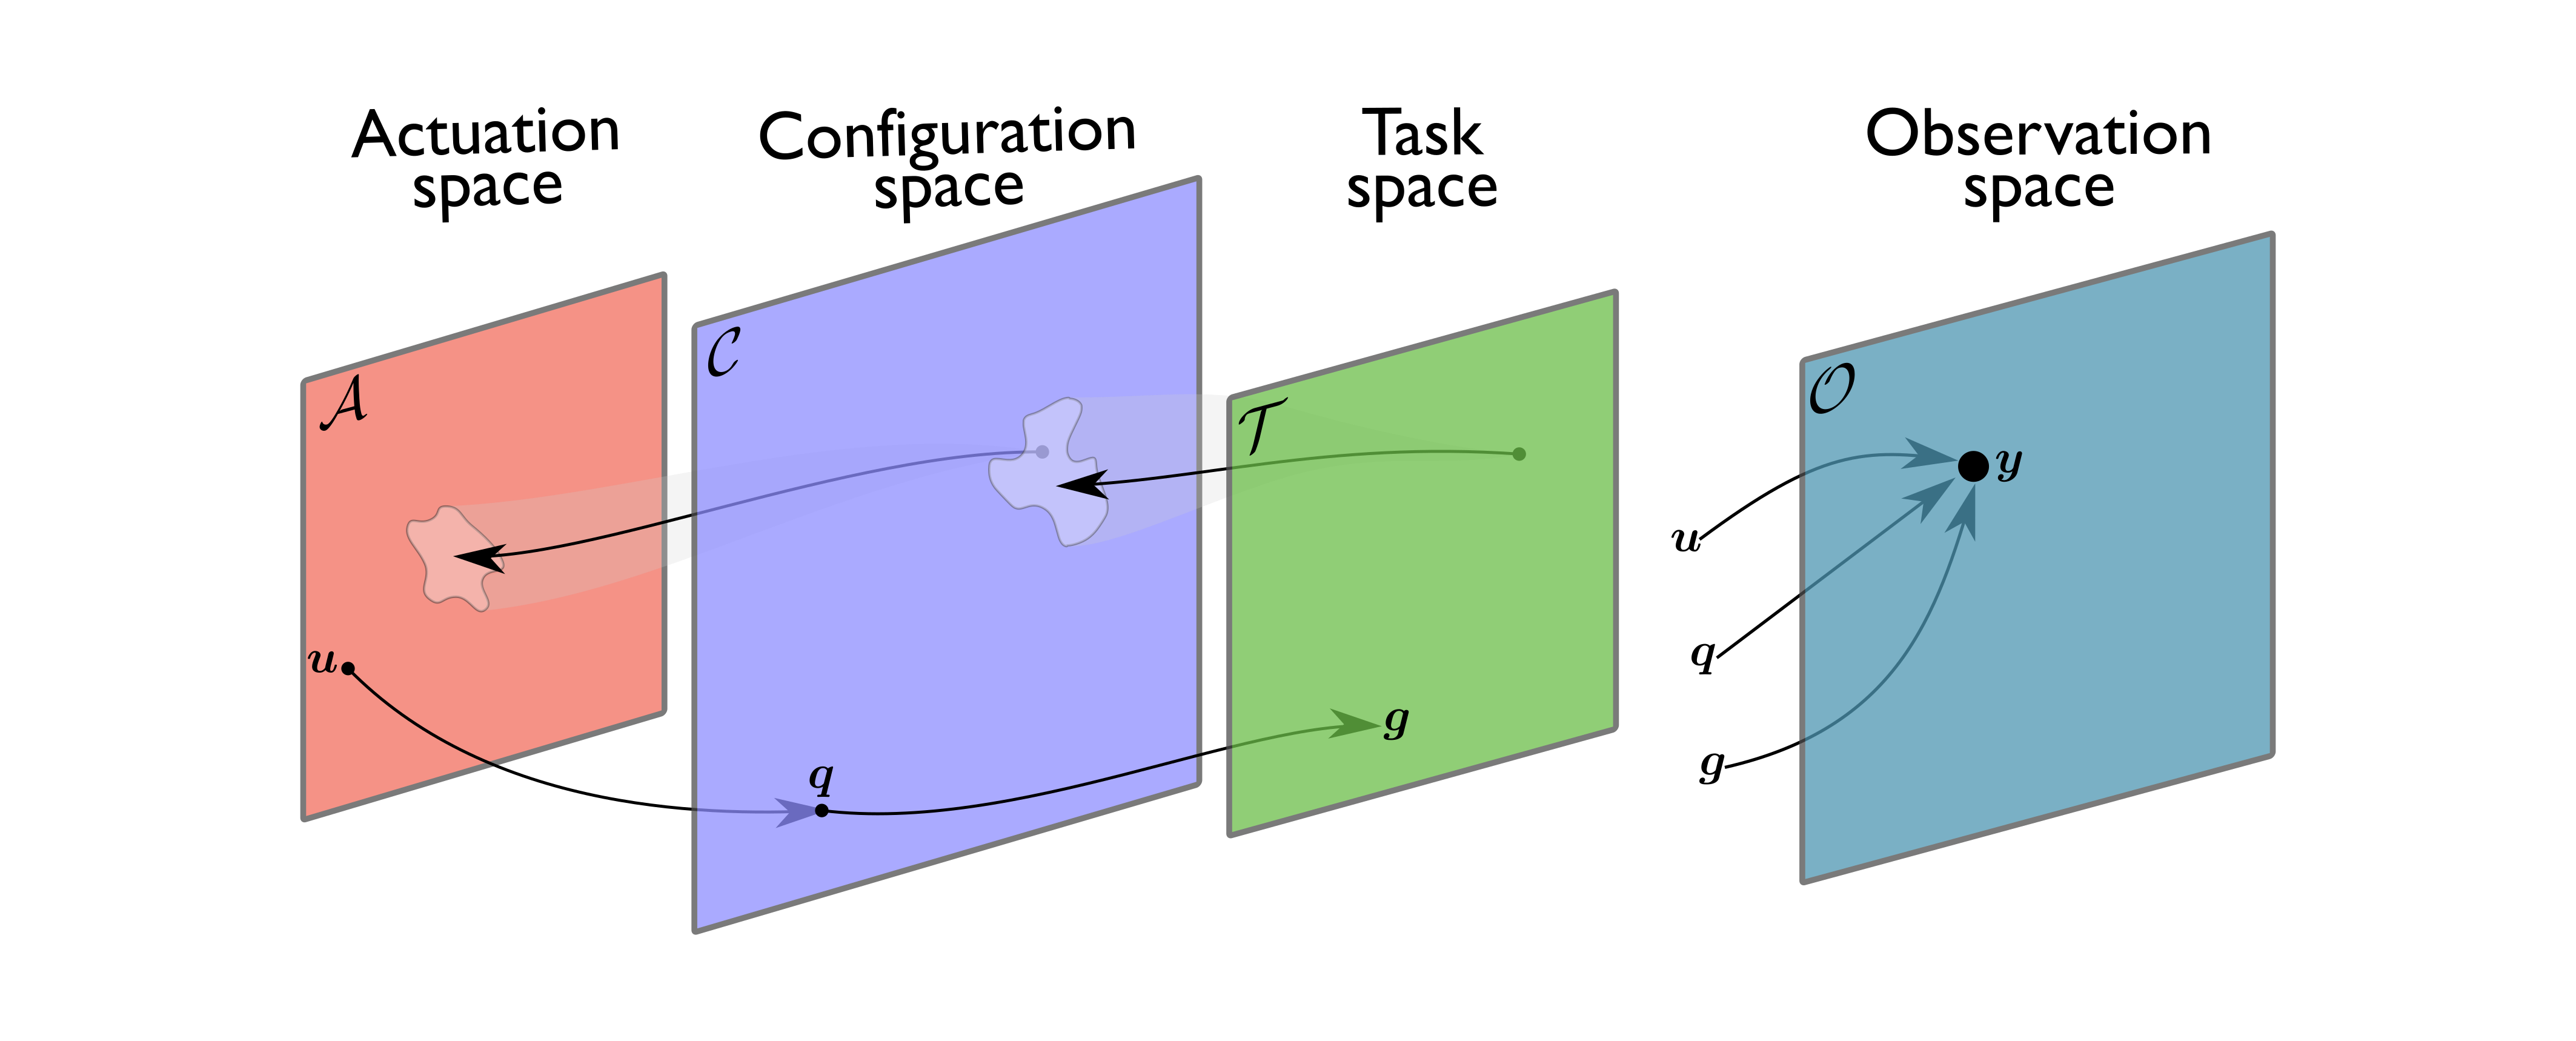
Learning Controllers for Continuum Soft Manipulators: Impact of Modeling and Looming Challenges
Egidio Falotico, Enrico Donato, Carlo Alessi, Elisa Setti, Muhammad Sunny Nazeer, Camilla Agabiti, Daniele Caradonna, Diego Bianchi, Francesco Pique, Yasmin Tauqeer Ansari, Marc Killpack Advanced Intelligent Systems, 2025 Paper A perspective article on the challenges for developing learning-based controllers for continuum soft manipulators with a focus on the impact of soft robot models. |
|
Pushing with Soft Robotic Arms via Deep Reinforcement Learning
Carlo Alessi, Diego Bianchi, Gianni Stano, Matteo Cianchetti, Egidio Falotico Advanced Intelligent Systems, 2024 Paper Developed a motor policy to control a continuum soft robotic arm to perform pushing tasks. Trained the policy in simulation using deep reinforcement learning, mitigating the sim-to-real gap with domain randomization, and transferred it to the real robot. |
|
| 2023 |
Ablation Study of a Dynamic Model for a 3D-Printed Pneumatic Soft Robotic Arm
Carlo Alessi, Egidio Falotico, Alessandro Lucantonio IEEE Access, 2023 Paper |
| 2023 |
Learning a Controller for Soft Robotic Arms and Testing its Generalization to New Observations, Dynamics, and Tasks
Carlo Alessi, Helmut Hauser, Alessandro Lucantonio, Egidio Falotico IEEE International Conference on Soft Robotics (RoboSoft), 2023 Paper |
Organized Workshops |